
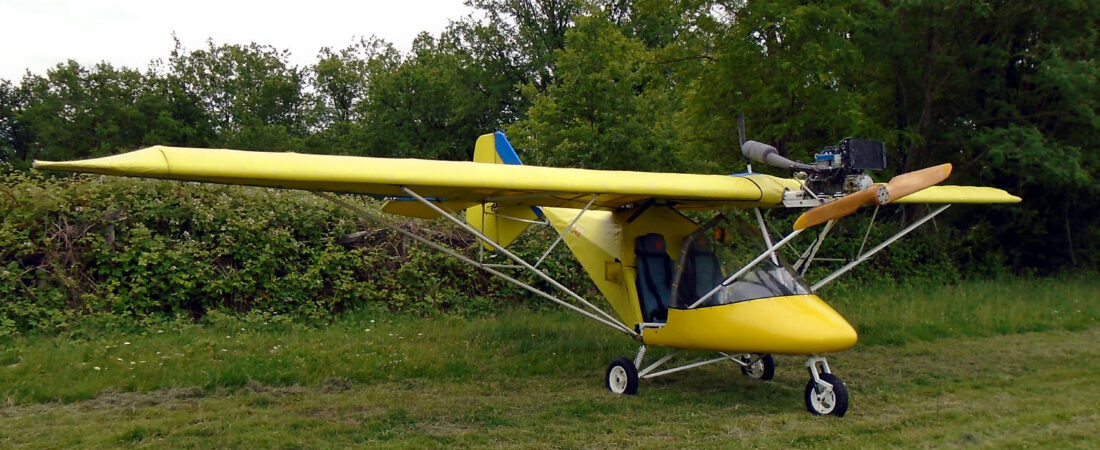


As Mike Tyson said, as did Joe Louis before him, ‘Everyone has a plan until you get hit in the face’. My plan for today was to finish fitting my Savannah’s new screen but that went by the board. For the past few days I’ve been arguing the toss with the supplier of my Isward lawn robot. As I mentioned previously, I’m now on my third machine after a mechanical failure with machine 1 and a software failure with machine 2 (the latter is now in my tool shed for ‘spare parts’ with a complete set of brand new accessories – charging station, charger and GPS beacon) and the current machine has been dogged by an irritating problem.
It has been refusing to dock as it should either mid-task in order to recharge its battery or at the end when it has finished the job. Instead it has returned to a position in front of the charging station and then aimlessly started slowly spinning around before finally coming to a complete halt. It has then been dropping off-line and if left it has then remained stationary until its battery has become totally depleted. This problem became my top priority because if I can’t get the robot working reliably again my lawns, which is how I laughingly describe them, will get out of control again, especially if we start to get more rain as the Autumn progresses, in which case I’ll have to start mowing them again with my ride-on instead of using the time to do more productive things.
I’ve shared photos and videos with the supplier who, if you ask me, has tried to take the easy way out ie by blaming me. He spotted that I have built a canopy over the charging station to protect it and the machine from the weather and he has suggested that it is preventing the machine’s camera from getting a clear view of the docking station’s position. I said no, it didn’t stop the other two machines. He then suggested that part of the canopy’s top cover was obscuring the ‘target’ on the rear of the charging station that shows the machine precisely where to dock but I said no it wasn’t, because neither of the other two machines were affected by it. So he then said that probably it was to do with the ambient light level. I replied funny that, because an evening or two before, the machine was finishing a mowing task in semi-darkness with its headlights on and had succeeded in docking just once having just prior turned its lights off.
I suggested that there were actually two more plausible explanations for the machine’s behaviour. The first was that when the machine successfully docked it had not long been recharged and was returning with a still highly charged battery as it was finishing off mowing just the last small area of grass. I’d noticed than when pausing to recharge mid task, this machine was doing so at a lower battery level than the other two machines and that it might therefore be running too long and returning to the charging station with a battery that was too low for it to then dock. The supplier denied that this could be the case. I therefore proposed the second explanation, which was down to ‘mapping’.
Old generation lawn robots use a physical wire either pegged to the ground or buried just below the surface in order to define the boundaries of the area to be mowed. RTK GPS machines like mine don’t do that and instead use precise GPS coordinates which are obtained by ‘driving’ the machine around the boundaries in record mode and saving a ‘map’ in the machine’s memory. I did this for machine 1 and although the supplier suggested copying the maps over from machine 1 into machine 2 when I received the latter in fact I did complete remaps from scratch for my two areas in back and front. But I didn’t do that for machine 3, which is giving all the problems. Instead as instructed by the supplier I’d copied the maps over.
I suggested that in my opinion the problem was that although the machine knew where the area boundaries were and followed them exactly it just had no idea where the charging station was. The supplier poo-pooed this but said that all I should do to make sure was enter mapping mode and reset the charging station’s position. I did this several times and after one of them the machine went berserk, missed the charging station by a mile and began climbing up the slope towards the rear of my house. The supplier told me to move the charging station. I said not likely as it had taken me long enough to create the present position and anyway, it worked fine for the other machines. I said that no, when I had the time I’d do a total remap from scratch of the boundaries, charging station position and no-go areas (trees and septic tank upstands in the lawn) of the larger lawn at the rear of my house and see what the machine did then.
And today was the day. And guess what? The machine performed impeccably, even docking mid-task to recharge with a battery level significantly lower than for either of the other machines. I told the supplier that copying maps from one machine to another using their established procedure obviously doesn’t work. I also told them, a bit tongue in cheek, that apparently I’m beginning to understand their machines better than they do but have not yet received a reply. I’ll be interested to see what they say when they do. So my original plan for today, to finish fitting my Savannah’s new screen, crashed and burned but hopefully I’ll be able to do that tomorrow. Unless something else turns up to disrupt it before then. 😕
 English
 Nederlands
 Français
 Deutsch
 Italiano
 Latviešu valoda
 Português
 Español